


Über den Kurs
⚠️ Required Add-on Module
To complete this course, activating the free "PID" add-on module in NiryoStudio is necessary. To activate it, please contact the NiryoSuccess team: customersuccess@niryo.com
Precision Pick & Place with Axis 5 PID Control
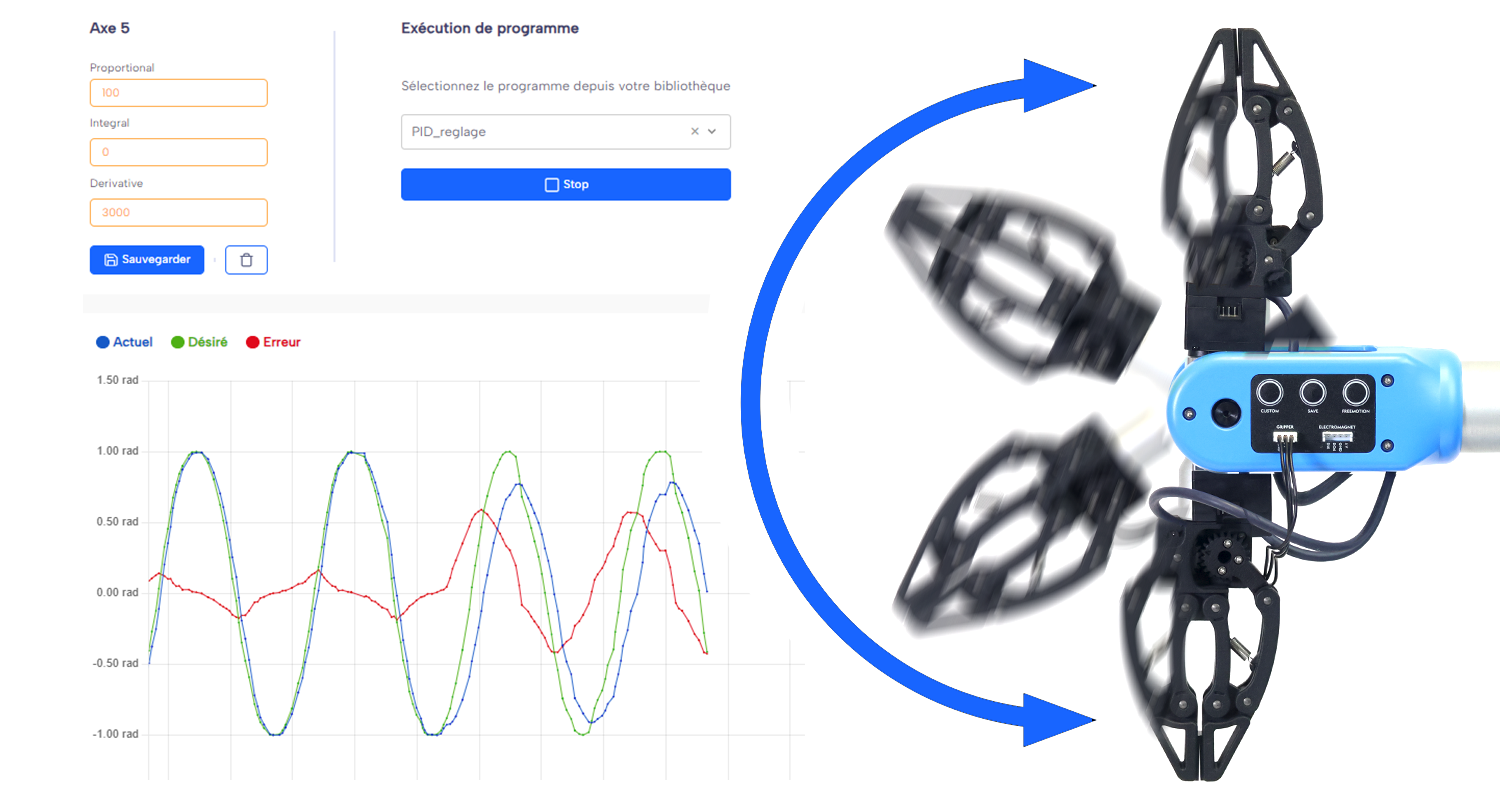
This hands-on activity extends the PID control workshop by applying theory to a real-world robotic challenge: achieving smooth and precise pick & place movements using the wrist joint (axis 5) of the Niryo robot.
Through guided experimentation, you’ll explore how proportional (P), integral (I), and derivative (D) gains affect motion behavior — from responsiveness and stability to precision. You’ll then apply your understanding to tune the PID parameters for a realistic industrial task: performing accurate and vibration-free pick & place operations.
The activity combines theory, experimentation, and creativity, culminating in a final challenge — stacking objects to form a stable tower using optimal PID tuning.
Lernziele
Kursinhalt
Zum Autor

Einschreibeoptionen
PID Tuning for a Pick & Place
- Length: 4h
- Content Type: Lab
- Programming: Blockly
- Equipment: Bundle STEM
⚠️ Required Add-on Module
To complete this course, activating the free "PID" add-on module in NiryoStudio is necessary. To activate it, please contact the NiryoSuccess team: customersuccess@niryo.com
Precision Pick & Place with Axis 5 PID Control
This hands-on activity extends the PID control workshop by applying theory to a real-world robotic challenge: achieving smooth and precise pick & place movements using the wrist joint (axis 5) of the Niryo robot.
Through guided experimentation, you’ll explore how proportional (P), integral (I), and derivative (D) gains affect motion behavior — from responsiveness and stability to precision. You’ll then apply your understanding to tune the PID parameters for a realistic industrial task: performing accurate and vibration-free pick & place operations.
The activity combines theory, experimentation, and creativity, culminating in a final challenge — stacking objects to form a stable tower using optimal PID tuning.
- Eingeschriebene Teilnehmer/innen: 43
- Length: 4h
- Content Type: Lab
- Programming: Blockly
- Equipment: Bundle STEM
This course includes
Arbeitsmaterial