


Code - Robot 5
Context
The code below presents the different steps involved in the detection of tokens on the Vision Set and the placement of square tokens onto the storage ramp without any specific sorting. The workspace used here does not correspond to the actual Vision Set workspace. It is a pre-defined workspace used only for the detection block, allowing the robot to determine whether a token is placed at a specific position so it can be picked up.
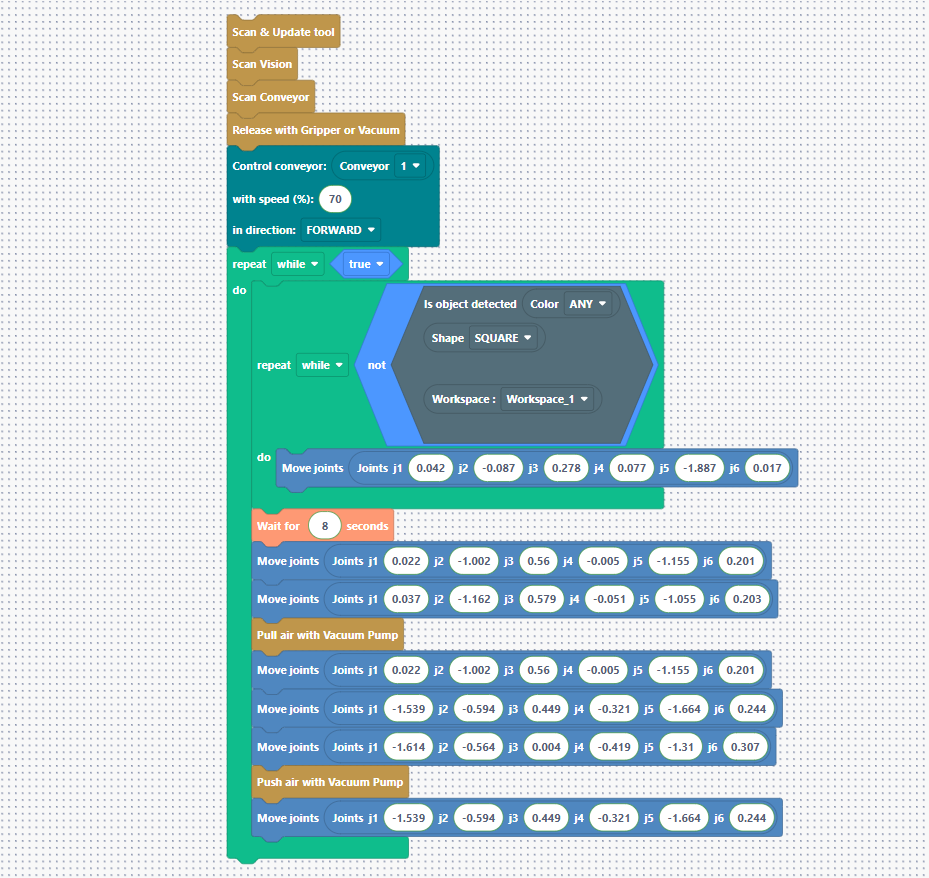
Initialization Outside the Loop
Before entering the loop, the robot prepares its environment:

-
It scans the tool, the vision system, and the conveyor.
-
For safety, it releases all air from its vacuum gripper to ensure proper handling during future picks.
-
The robot initially commands Conveyor 5 to run continuously at 70% of its maximum speed in the forward direction, in order to transport screws toward the screw bin.
Vision-Based Waiting Loop
Once inside the main loop, the robot enters an active waiting sub-loop:

-
Condition: As long as the camera does NOT detect a square token in the Workspace_1 area, the robot remains in its high observation position, stationary above the conveyor, with the camera focused on the vision area.
Decision Making and Timing
As soon as a square token enters the camera’s field of view:
-
The sub-loop condition is no longer satisfied, and the robot exits its waiting state.
-
The robot waits for 8 seconds to allow Robot 4 to place the token on the Vision Set, preventing any collision.
Square Pick Operation
Once the 8-second delay has elapsed, the pick sequence begins:
-
Approach: The robot moves down toward the token.
-
Suction: The vacuum pump is activated to securely grip the square token.
Transfer and Placement on the Ramp
The square token is now securely held:

-
Clearance: The robot lifts to its intermediate safe height.
-
Move toward the ramp: The robot moves toward the storage area. Note that an intermediate position is used to avoid collisions with Robot 1 if it is operating above Conveyor 5.
-
Descent onto the ramp: The robot moves down to place the token at ramp level.
-
Release: The robot reverses the airflow to release the square token cleanly onto the ramp.
-
Final retreat: The robot moves back up to its safe position above the ramp, then the main loop restarts. It immediately returns to its waiting position, ready for the next square token.
Summary
Robot 5 starts Conveyor 5 at 70% speed to transport screws. It remains fixed in a high observation position and monitors the Vision Set. As long as no square is detected, it does not move. As soon as a square appears, it waits 8 seconds (allowing Robot 4 to place the part and clear the area), then descends to pick it up using its vacuum gripper, moves to the ramp to place it in the storage area, and finally returns to its waiting position.